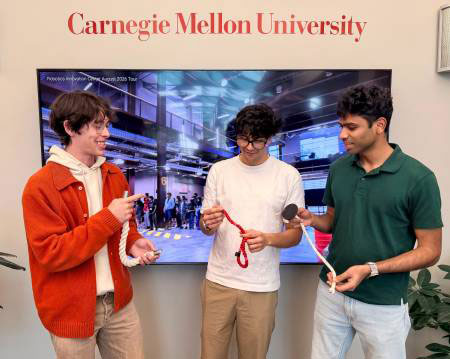
Jakobsson left , Mahajan center and Pullalarevu right interact with the small sections of rope that they used to test the Wiggle and Go system.
Jakobsson (left), Mahajan (center) and Pullalarevu (right) interact with the small sections of rope that they used to test the Wiggle and Go system. Researchers in Carnegie Mellon University’s Kenneth C. Griffin School of Computer Science have developed a system to help robots better handle ropes and cables to improve how they operate in situations like manufacturing, construction, search and rescue, environmental monitoring and healthcare. Called Wiggle and Go, the method enables a robot to briefly wiggle a rope or cable, observe how it responds, and estimate its physical properties. With that information, the robot can plan its movements more reliably without practicing the task first. “Rigid objects effectively have six degrees of freedom,” said Jeffrey Ichnowski, an assistant professor in CMU’s Robotics Institute. “With ropes or cables, you effectively have infinite degrees of freedom. A rope or cable can bend, twist and stretch along its entire length, making its shape and movement much harder to predict.” Their physical properties add another layer of difficulty. Two ropes or cables can respond differently to the same movement, depending on their length, weight and stiffness. A robot cannot determine those properties simply by looking at the rope or cable, yet it needs to understand how the object will behave to move it. That’s where the wiggle comes in. With Wiggle and Go, the robot gives the rope or cable a quick wiggle while an overhead camera records how the resulting wave travels through it. Computer vision algorithms track the movement, and a model uses that information to estimate physical properties that help explain its behavior. The robot then uses those estimates to plan how it will move the rope toward a goal or to manipulate it into a desired position. Rather than repeatedly attempting a task and adjusting its movements after each failure, the robot uses what it learns from the initial wiggle to plan its action. This ability could be especially valuable when a second attempt is not an option. The research team pointed to the example of a robot throwing a rescue rope to someone in danger in the water. A failed attempt could have serious consequences, making it important to predict how the rope will move before acting. Making the system work on a physical robot was the team’s biggest challenge to overcome. The team trained its model entirely in computer simulation, where researchers can develop and test robotic behaviors without repeatedly using physical hardware. “Simulated objects do not always behave exactly like their real-world counterparts,” said Arthur Jakobsson, a master’s student in the Robotics Institute. “We trained our model entirely in simulation, then used the rope’s movement during the initial wiggle to estimate its physical properties and improve the system’s predictions, allowing the robot to plan movements more accurately in the real world.” The project grew out of collaboration across the Robotics Institute’s graduate programs. Jakobsson, studying in the Master of Science in Robotics program, met co-authors Abhinav Mahajan and Karthik Pullalarevu, students in the Master of Science in Computer Vision program, in a class. They recognized that their different areas of expertise could help them approach the problem from complementary angles. Jakobsson brought experience working with robots, while Mahajan and Pullalarevu contributed expertise in computer vision, including tracking and interpreting movement in images. Combining these skills helped the team connect what a robot sees with how it should move. “Sometimes, a simple exchange of ideas can lead to something bigger than what you could accomplish on your own,” Mahajan said. “We each brought different skills to the table, and combining them allowed us to find a way to help robots better understand how things move in the real world.” Wiggle and Go was partially funded by the National Science Foundation and was accepted to the 2026 Conference on Robotic Learning next month in Austin, Texas, where Jakobsson will present the team’s research. To learn more about Wiggle and Go, visit theproject website. For More Information:Aaron Aupperlee | 412-268-9068 | aaupperlee@cmu.edu